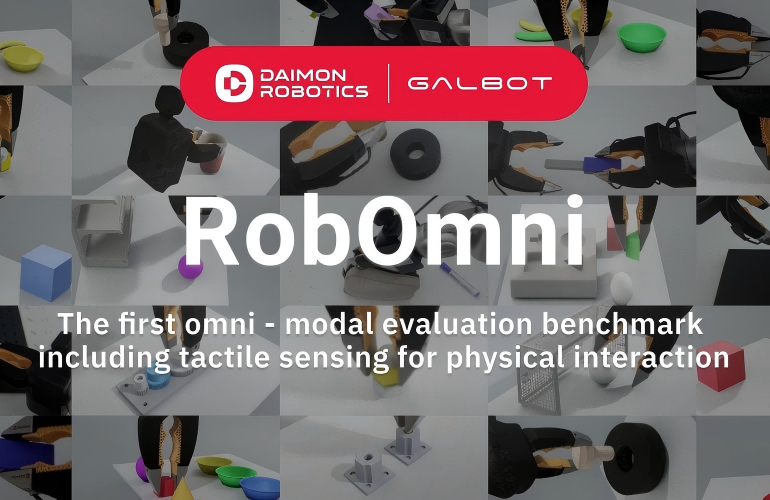
Daimon Robotics, an embodied intelligence company from Hong Kong, unveiled RobOmni at ICRA2026 as a standardized benchmark for evaluating tactile perception and dexterous manipulation. The platform is built on NVIDIA Isaac Sim and provides omni-modal information including high-resolution fingertip tactile sensing, wrist-mounted RGB vision, gripper status, TCP trajectories, action commands, and external camera observations.
RobOmni supports tactile ablation testing, allowing developers to evaluate robot policies with and without tactile information to measure how tactile sensing directly contributes to task performance. The benchmark evaluates multiple dimensions: task success rate, manipulation efficiency, dexterous manipulation capability, operation failure events (slip, jamming, collision, retry), and generalization robustness across dozens of manipulation scenarios such as grasping, placement, precision insertion, and component assembly.
The industry previously lacked a unified evaluation framework for tactile intelligence in contact-rich manipulation, making it difficult to compare systems or measure progress. RobOmni addresses this gap by providing a common standard and helping establish a data flywheel of data accumulation, capability validation, and model iteration to accelerate industry development.
Summaries like this, in your inbox every morning.
Pick your industry and the AI tools you use, and get news related to your work every day.
Free · 30 seconds with Google · unsubscribe anytimeWhat is AIToday? →
Ask AI anything about this article. The AI reads this article, earlier AIToday articles, and Wikipedia, and cites its sources. Q&As are published on this page for other readers too.
AIBotics completed its acquisition of NovaCore Labs' operating assets from PlayJamaica Limited, gaining 10 ser…
In an internal test, Google DeepMind robotics researchers instructed Gemini 4 Argon to watch a video of a huma…

Amulya Vishwanath, who spent seven years leading product marketing for Nvidia's robotics platforms, says robot…
Claire interviewed Rika Antonova of the University of Cambridge on the Robot Talk podcast about using AI to de…
An essay argues that after language models spread through cognitive work like writing and accounting, AI is no…

Skild AI used Nvidia Isaac Sim to give its S1 model one objective — score a goal — and let it compete against…


