What happened
Dream Machines fine-tuned Physical Intelligence's open-source π0.5 model on an industrial assembly task; 240 human recovery rollouts raised success from 24% to 88% with under two hours of training data, and Real Time Chunking settings reached ninety-eight percent insertion success.
Why it matters
Human corrections and data diversity beat raw demonstration volume for reliability, suggesting robotic automation teams can cut machine-training spend by targeting edge-case interventions rather than recording dozens of repetitive hours.
What to watch
The 88% figure comes from the team's physical evaluations, so whether it holds outside that setup is the test; watch how Real Time Chunking parameters and execution blending carry into other tasks.
WHO IT HITSRobotics engineers and automation teams building physical AI assembly systems benefit most, since the result shows that investing in edge-case human interventions can lift reliability far faster and more cheaply than collecting more repetitive demonstrations.
Summaries like this, every morning.
The result matters less as a single benchmark than as a signal about where robotics data budgets do the most work. The Dream Machines team collected teleoperation data across multiple desks using Gello controllers and virtual reality headsets, then found that data quality and visual diversity improved reliability faster than simply recording dozens of repetitive demonstration hours. That is the interesting part: the expensive thing in industrial automation has long been collecting more and more demonstration data, and this outcome points the other way.
The gains came from introducing human corrections into the training pipeline, with 240 recovery rollouts doing the heavy lifting. Full model fine-tuning outperformed low-rank adaptation methods on physical success rates, and Real Time Chunking settings from Physical Intelligence pushed final insertion success to ninety-eight percent during evaluations.
For companies developing robotic automation, the practical reading is that spending on edge-case interventions and execution blending parameters may buy more reliability than volume. Whether the 88% and ninety-eight percent figures carry into different tasks, hardware, or less controlled environments is the open question, since these came from the team's own physical evaluations.
Pick your industry and the AI tools you use, and get news related to your work every day.
Free · 30 seconds with Google · unsubscribe anytimeWhat is AIToday? →
Ask AI anything about this article. The AI reads this article, earlier AIToday articles, and Wikipedia, and cites its sources. Q&As are published on this page for other readers too.
MomongaCode is out under the MIT license, a terminal AI coding agent that works with Ollama, LM Studio, and Ap…
Robotics and physical AI companies have raised nearly $48 billion in 2026, but VulcanForms CTO Michael Kenwort…
Seizo Trend's analysis lays out SoftBank's approach to physical AI, where the company positions itself to earn…
Japan launched a national 'physical AI' initiative that gathers many of its major companies, with Honda standi…
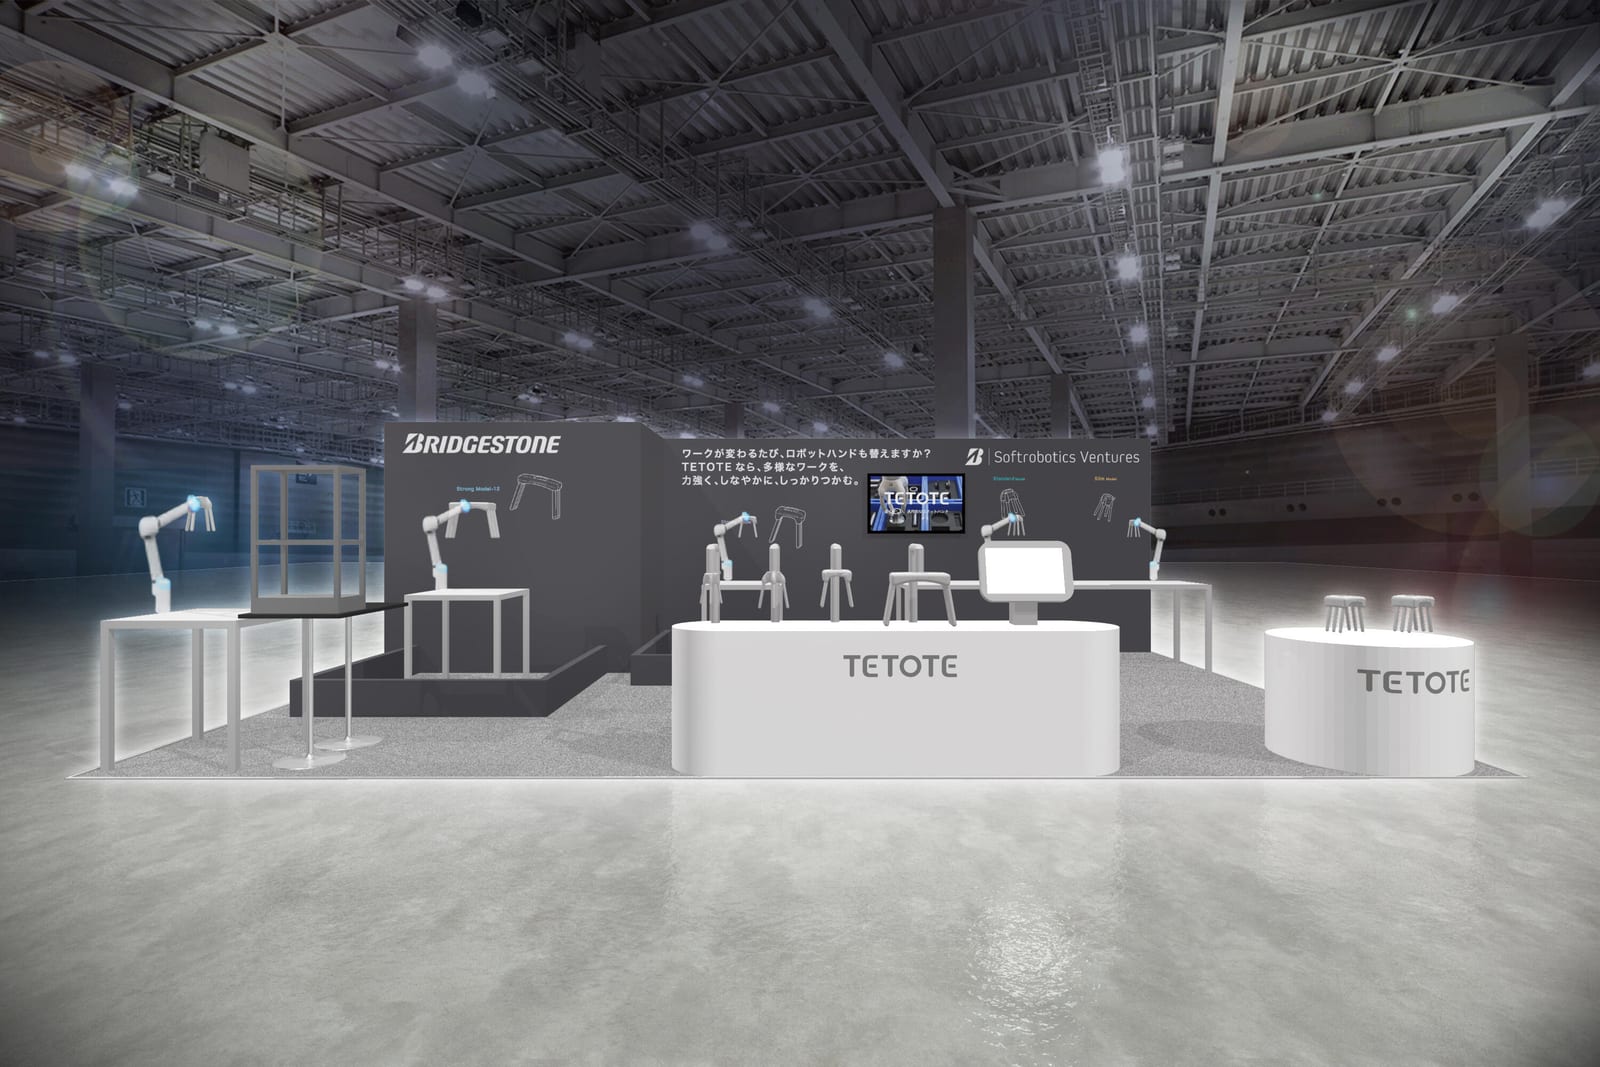
Bridgestone announced it will exhibit its full TETOTE product lineup at RoboNext2026 and debut a new demonstra…
Gyro Governance Lab released AIR Office, a desktop app for AI safety research that runs agentic chat on the Mi…