What happened
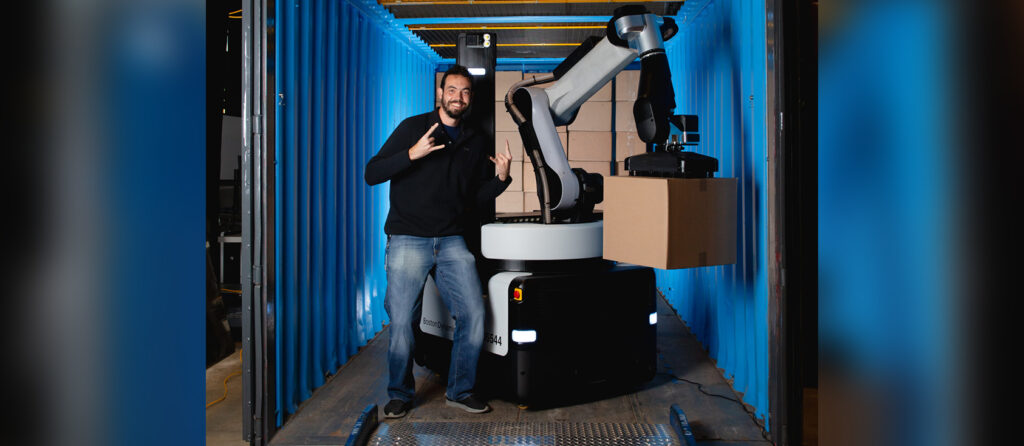
Sebastian Castro, an independent roboticist specializing in robotic manipulation, spoke with Robot Talk about developing open-source software for robot task planning and behaviour.
Why it matters
His work focuses on making software for how robots decide and act publicly available, which could lower the barrier for others building similar systems.
Summaries like this, every morning.
Sebastian Castro's appearance on Robot Talk centers on a practical niche: open-source software that helps robots plan tasks and decide how to behave. That focus on behaviour and planning sits alongside his specialization in robotic manipulation, suggesting the conversation likely touched on how robots translate decisions into physical action.
Beyond his independent work, Castro has a background that spans software engineering roles at several robotics organizations and science labs, as well as education marketing. He also contributes to robotics education through blog posts, open-source software, mentorship, talks, and workshops. This mix of hands-on engineering and outreach may inform how he approaches making robot software accessible to a broader community.
Pick your industry and the AI tools you use, and get news related to your work every day.
Free · 30 seconds with Google · unsubscribe anytimeWhat is AIToday? →
Ask AI anything about this article. The AI reads this article, earlier AIToday articles, and Wikipedia, and cites its sources. Q&As are published on this page for other readers too.
Hitachi, Macnica and J-Power said on November 19 they agreed to jointly study a physical-AI development platfo…
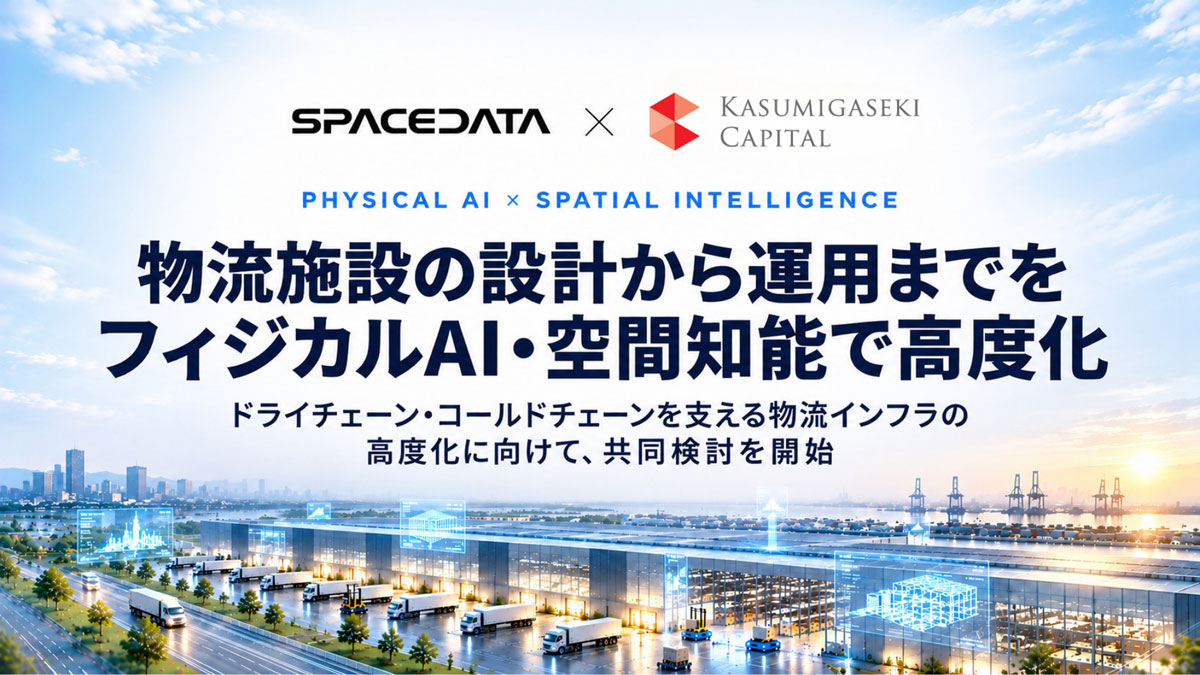
霞ヶ関キャピタル and スペースデータ will jointly study applying フィジカルAI at three of Kasumigaseki Capital's logistics faciliti…
Pan-International Industrial Corp
The FCC voted November 19 to adopt rules covering the 450 MHz band for aviation communications, the 24 GHz ban…
SkyeBrowse updated its 3D mapping platform with "Realistic 3D," which the company says processes video three t…
Klakix released Klakix Bridge, a free GPL-3.0 add-on for Blender 4.2 and later that connects the open scene to…