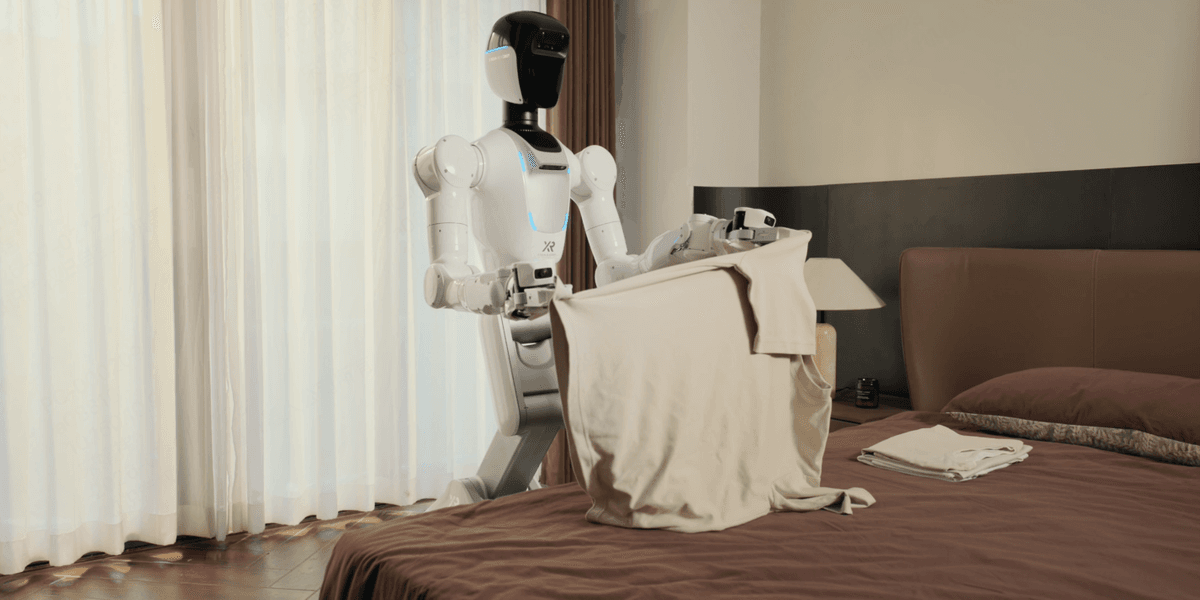
What happened
X Square Robot, a Chinese embodied-AI company, has unveiled an integrated foundation stack for robotics spanning data collection, a world model (WALL-WM), and an action model (Wall-OSS-0.5). The company is releasing the code openly and argues this layered approach—organized around physical events rather than fixed time slices—solves robotics' core problem: how to build capability that transfers across tasks and machines. The company's valuation has climbed above 20 billion yuan (about US $2.9 billion(約4600億円)).
Why it matters
Robotics has long assembled separate perception, planning, and control modules that don't generalize, unlike large language models which scale predictably. X Square's bet is that data quality and infrastructure, not model size, are the real bottleneck for general-purpose robots. The company reports reaching performance comparable to an all-robot dataset at roughly a 20-fold lower cost by pretraining on robot-free human demonstrations captured via wearable rigs, then anchoring to real-robot data. If validated independently, this cost reduction could reshape robot training economics.
What to watch
The company's strongest results are currently measured on its own robots and benchmarks. With code now released, the broader robotics community will test and reproduce these capabilities across different robots, tasks, and settings—a crucial step to confirm whether the stack's principles hold beyond X Square's controlled environment.
Summaries like this, in your inbox every morning.
The robotics field has long struggled with a fundamental problem that large language models solved: how to build systems that generalize. Where LLMs benefit from pretraining on broad data and then fine-tuning for specific tasks, robotics has historically cobbled together separate perception, planning, and control modules that rarely transfer knowledge across different robots or tasks. X Square Robot's explicit wager is that the solution lies in an integrated stack where data infrastructure, world modeling, and action generation are tightly coupled from the ground up.
The company's diagnosis—that data quality, not model size, is the real bottleneck—reflects a pragmatic shift in how the embodied-AI field is thinking about scaling. By using inexpensive wearable rigs to capture human demonstrations, then validating them through physical playback on real hardware, X Square claims to have cracked a cost problem that has long made robot learning expensive. The reported 20-fold reduction in data collection cost, if confirmed independently, would reshape the economics of robot training. Equally important is the architectural choice to organize the world model around semantic events—coherent behaviors like grasping or placing—rather than fixed time windows. This design respects what large video models already know while still yielding executable motion, a middle ground between pure prediction and pure control.
The fact that X Square's valuation has exceeded US $2.9 billion(約4600億円), and that the company is releasing code openly, signals confidence among investors that data infrastructure and foundation models will be long-term differentiators in embodied AI. However, much of the current evidence comes from the company's own robots and benchmarks. The next phase—independent testing and reproduction across a wider range of robots, tasks, and settings—will determine whether these principles truly generalize or remain specific to X Square's carefully controlled environment.
Pick your industry and the AI tools you use, and get news related to your work every day.
Free · 30 seconds with Google · unsubscribe anytimeWhat is AIToday? →
Ask AI anything about this article. The AI reads this article, earlier AIToday articles, and Wikipedia, and cites its sources. Q&As are published on this page for other readers too.
Hewlett Packard Enterprise stock is down 5% at $55.87

The Motley Fool argues Amazon is the AI company of the two, since AWS was just 21% of first-half 2026 revenue…

OpenAI is launching the Rosalind Academic Plan, offering eligible research labs at US universities up to 30 fr…
Google Deepmind's Gemini 4 Argon scored 97.5 percent on ARC-AGI-3 at a cost of $4,800, second only to GPT-6 As…

Cammarata reinterprets InceptionV1's cat-car neuron as a V-shape detector, not two unrelated concepts

Microsoft's Surface Laptop Ultra, using Nvidia's RTX Spark platform, starts at $2,599 (up to $5,899)


