What happened
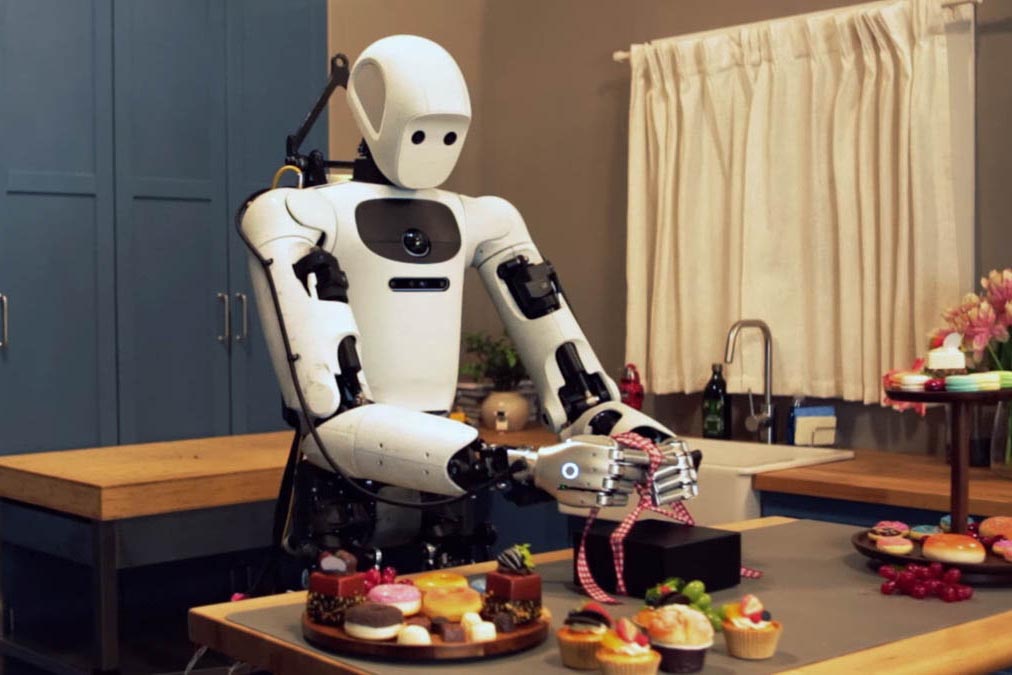
UC Berkeley and NVIDIA released open-source tools, including Graph-as-Policy and the VABAR benchmark of six industrial tasks, that let AI coding agents write, simulate, and refine robot programs.
Why it matters
The tools aim to cut robot programming from weeks to hours by letting agents iterate in simulation, as shown when GPT-6 Astra generated a Newton simulation from a video in about an hour.
What to watch
Researchers presented the concept at CoRL 2026 this week in Austin, Texas.
WHO IT HITSRobotics engineers and industrial automation teams could see programming and troubleshooting time drop, since the tools let agents write and test code in simulation before deployment.
Summaries like this, every morning.
The release stems from a practical bottleneck in industrial robotics: programming, tuning, and troubleshooting workcells has traditionally taken weeks to months, and software teams often start only after hardware is installed, putting them under deadline pressure.
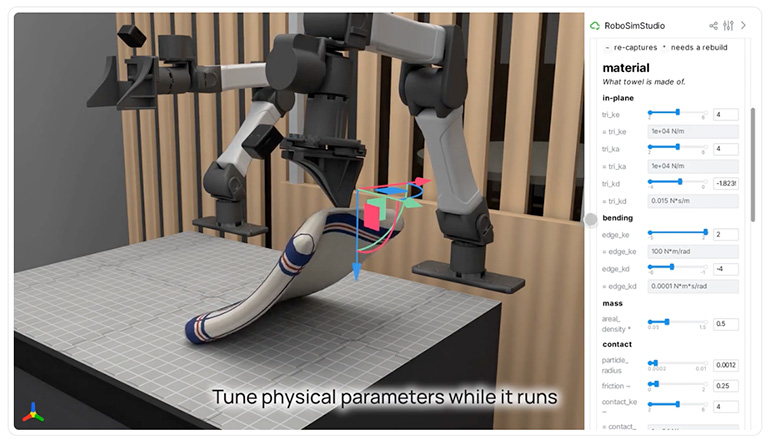
The tools address this by combining a modular framework, Graph-as-Policy, which splits tasks into skills like perception, grasp planning, and collision-free motion, with a benchmark, VABAR, that measures progress on six practical manipulation tasks. A key enabler is RoboSimStudio, an interface built by graduate student Eric Chen that makes the hundreds of parameters in the Newton physics engine tractable. According to Goldberg, when Chen gave GPT-6 Astra the tool and a video in September, it produced a Newton simulation closely matching the video within about an hour.
Industry collaborators are already evaluating the approach. Bosch Research is assessing agentic robotics for diverse industrial automation scenarios, and Ambi Robotics reported increased throughput across its U.S. fleet while keeping engineers in control.
Pick your industry and the AI tools you use, and get news related to your work every day.
Free · 30 seconds with Google · unsubscribe anytimeWhat is AIToday? →
Ask AI anything about this article. The AI reads this article, earlier AIToday articles, and Wikipedia, and cites its sources. Q&As are published on this page for other readers too.
Plurai raised $13 million in seed funding led by Team8, with U&I, Velocity and Mercer participating, to build…
AWS released UAEF, an open-source system that normalizes agent traces from LangGraph, LangChain, Strands Agent…
Outlier launched a notarized Mac app, free for Nano and Lite tiers, with a $49 once Pro license that unlocks a…
The write-up compares a few-line Python L−R implementation that subtracts the right channel from the left with…
At the AI Engineer Code Summit, OpenAI's Dominik Kundel and Charlie Guo demonstrated asking Codex to push a br…
Google DeepMind released Gemini Robotics 2.5, a vision-language-action model tested on over 200 tasks like tyi…